Real-Time Edge Perception
Vehicle-mounted vision and depth at 20+ FPS: object detection, distance estimation, hardware-accelerated encoding, all on a single edge device.
#Computer Vision
#Edge AI
What it does
A vision system mounted on a moving vehicle identifies objects in its path, estimates the distance to each one in metres, and produces an encoded video stream of the annotated scene — all in real time on a single edge device. The detection labels and distance estimates feed back to the vehicle’s control loop; the encoded video feeds back to a monitoring station.
Why edge
The latency budget between “see the object” and “act on the object” is too tight for any round trip to the cloud. Edge inference is the only viable answer. The interesting engineering is everywhere but the model: hardware-accelerated decoding, async multi-stage pipelines that don’t drop frames, depth sensing in lighting conditions that the factory floor wasn’t designed for.
Architecture
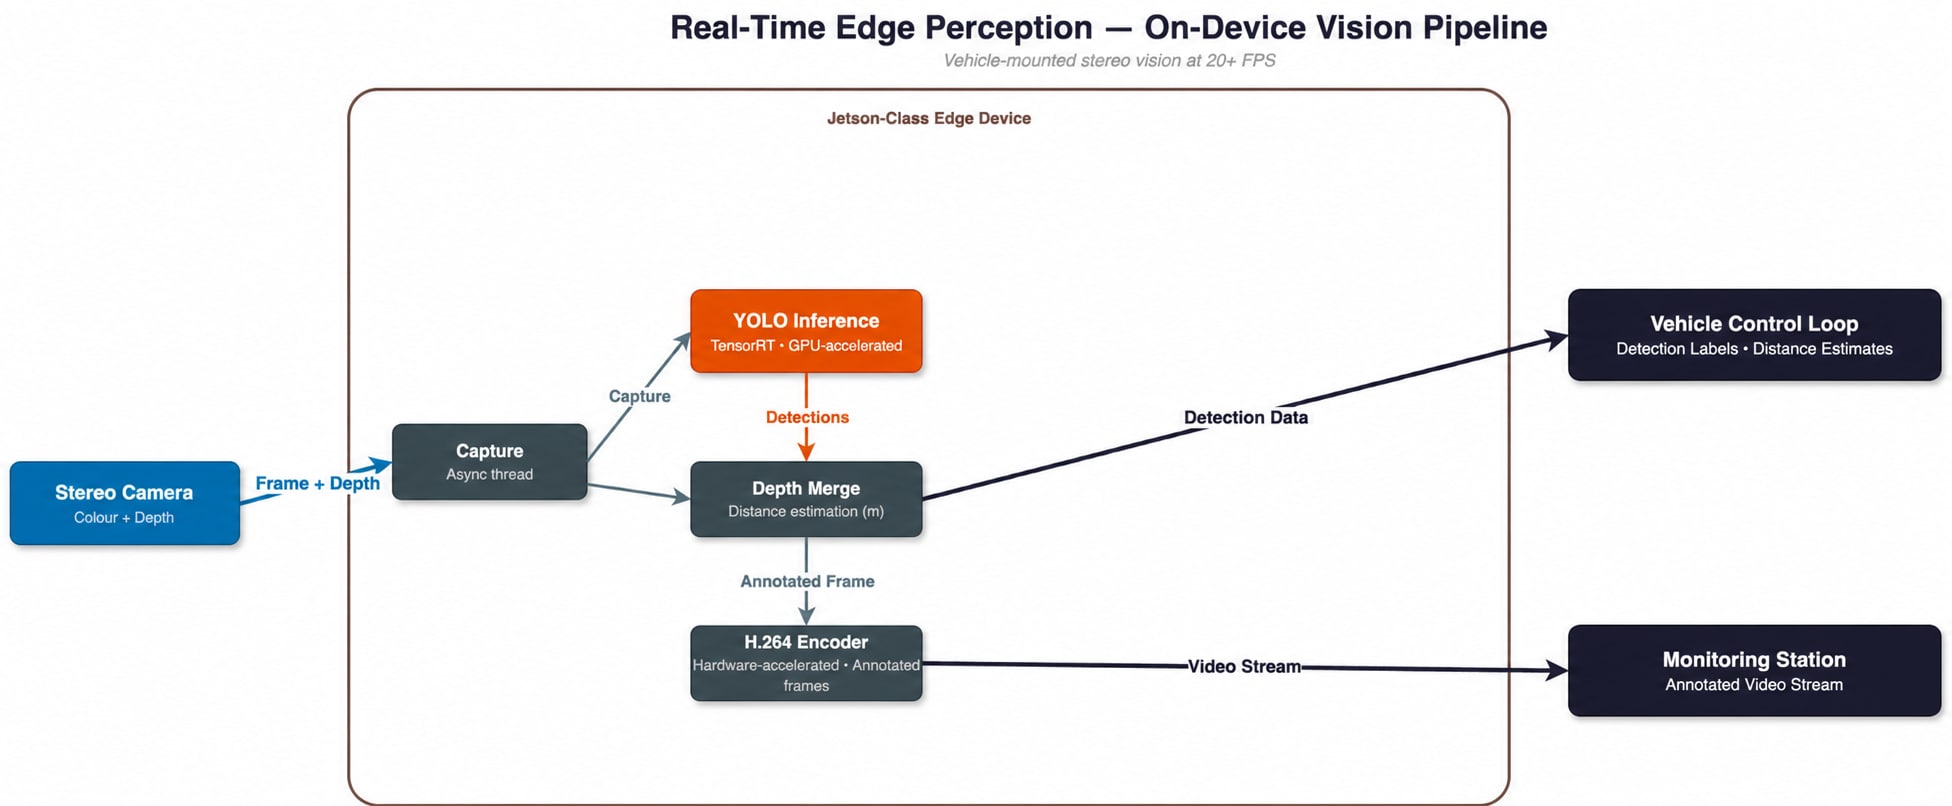
Stereo Camera → Capture → YOLO Inference + Depth Merge → H.264 Encoder → Vehicle Control Loop + Monitoring Station
YOLO object detection with TensorRT acceleration on a Jetson-class edge device.
Depth-enabled stereo camera providing RGB and distance data.
Async pipeline: capture → inference → depth merge → encode → publish, with each stage on its own thread.
Hardware H.264 encoding so CPU never becomes the bottleneck
Use Cases
1. Pallet Detection
The custom pallet detector identifies pallets, pallet pockets, and surrounding rack context, classifies the pallet’s handling state, and feeds position and state back to the vehicle’s control loop.
2. Roll Core Detection
The roll core pipeline locates paper roll cores and core centres in the vehicle’s path, estimates distance in metres, and feeds annotated distance output to the monitoring station.
WHAT'S BEHIND THE NDA
Client name and live inference footage — real-time detections with bounding boxes, labels, and confidence scores recorded on an active factory floor — available under NDA.