Agentic Fleet Router
Natural-language instructions become routing constraints in a moving AGV fleet, using Model Context Protocol as the bridge between operator intent and fleet routing.
#Agentic Workflow
#Natural-Language Interface
SEE IT IN ACTION
What it does
An operator types a plain-English instruction (“keep vehicles out of aisle 3 while maintenance is running”) and the system translates that intent into a live constraint on the fleet’s routing graph. The next AGV that would have passed through that zone gets rerouted automatically. No ticket, no API call, no supervisor in the loop.
The interesting part is how. There’s no rule engine, no DSL, no chatbot. There’s an LLM handed a small, well-typed set of tools via the Model Context Protocol (MCP). The LLM reads the operator’s instruction, picks the right tool, calls it with the right arguments, and the tool updates the routing graph’s edge weights. The underlying routing algorithm never changes — only the inputs do.
When the action carries risk, the system pauses and asks a human to approve before executing. That approval loop is built in, not bolted on.
Why it matters
Floor operators know the warehouse. They shouldn’t have to know graph theory, or file a change request, or wait for a planner to update a spreadsheet.
This pattern (natural-language instruction in, precise operational action out) applies wherever humans need to influence a running automated system in real time: rerouting around a spill, deprioritising a lane during a shift handover, responding to an unexpected equipment fault. The pattern is the same. Only the toolset changes.
Zero changes to your existing FMS
This is the key point: we don’t touch your Fleet Management System.
The agent layer sits entirely above the existing infrastructure. It reads fleet state through the FMS’s own published API (vehicle positions, move costs, fault codes) and writes back through the same API your operators already use. The FMS, the routing algorithm, the PLCs, the AGV firmware: none of it changes.
What we add is a thin, stateless AI layer:
An MCP server that wraps your FMS control operations as typed tools the LLM can call.
A LangGraph agent that polls fleet state, reasons about it, and decides whether to act.
A HITL approval gate that intercepts high-impact actions and holds them until a human confirms.
The FMS sees normal API calls. The agent is just another client.
Architecture
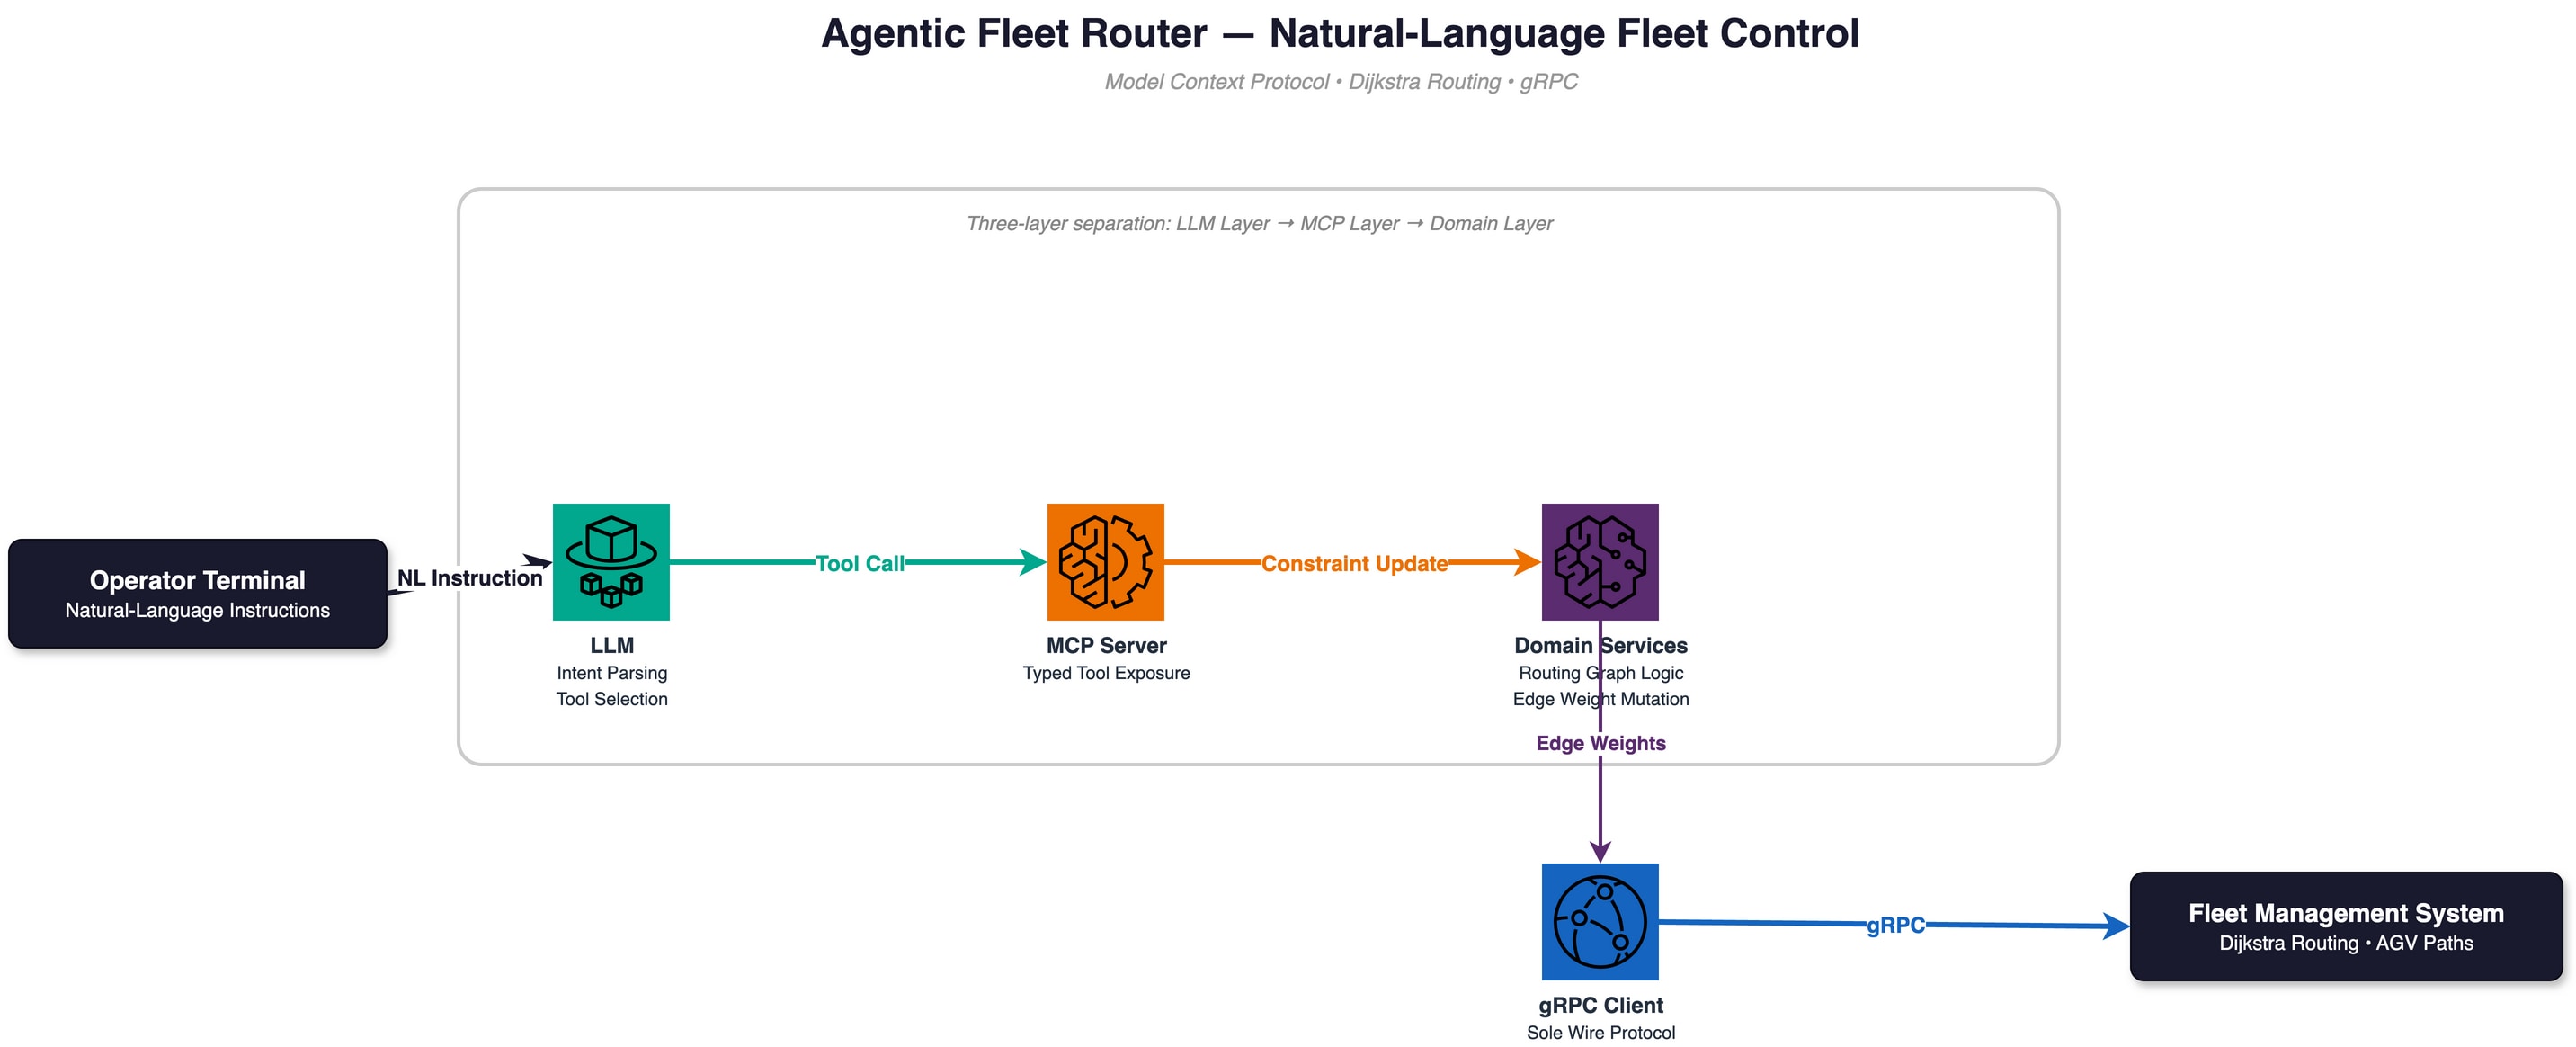
NL Instruction → LLM → Tool Call → MCP Server → Constraint Update → Domain Services → gRPC → Fleet Management System
The FMS/VMS is untouched. The agent consumes its API as a read/write client — nothing more.
MCP as the contract. Tools are typed, versioned, and audited. The LLM can only call what’s been explicitly exposed.
Routing Algorithm is a black box. We modify edge costs and zone constraints; the routing algorithm itself is never changed.
HITL is structural, not optional. High-impact actions pause the graph and wait for human confirmation before execution.
Audit trail by default. Every reasoning step, every tool call, and every human decision is logged.
Turn operator intent into live routing constraints for AGV fleets.